Showing Posts From
Medtech
-
 Amara Okafor
- 14 Sep, 2026 21:52
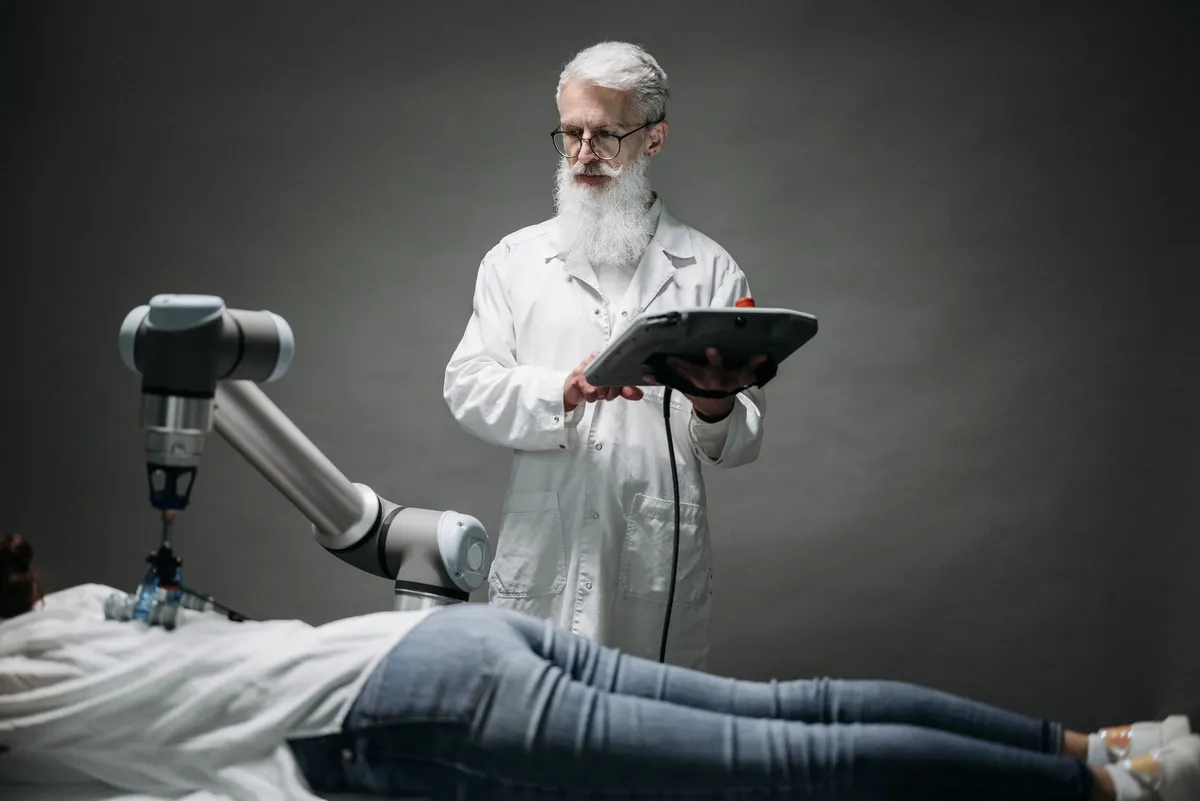
The Digital Scalpel: Architecting High-Fidelity Haptic Feedback in Robotic Surgery Simulation
Bridging the Proprioceptive Gap in Digital Surgery In the theater of modern operating rooms, the transition from tactile, manual control to teleoperated robotic platforms has redefined the limits of human intervention. Yet, as we shift the locus of agency from the surgeon's fingertips to a console interface, we face a critical physiological crisis: the loss of haptic transparency. When a surgeon operates via the Da Vinci or newer autonomous-assisted systems, the visual data is rich, but the kinesthetic feedback—the "feel" of tissue resistance, arterial pulsatility, or the subtle crunch of calcified plaque—is frequently attenuated or entirely abstracted. As an engineer witnessing the convergence of high-frequency sensors and machine learning, I have long argued that our current surgical simulation frameworks are insufficient. We are not merely building games; we are constructing high-stakes digital twins of human biology. The challenge of simulating surgical precision lies in the intersection of physics-based rendering (PBR) and low-latency motor control. When a trainee manipulates virtual tissue, the feedback loop must occur within the human perception window—typically under 10 milliseconds—to ensure that the brain does not register the interaction as a digital artifact. If the loop latency exceeds this, the cognitive dissonance destroys the fidelity of the simulation. This article dissects the architecture of these systems, moving past mere visualizations into the tangible physics of force-feedback interfaces that are currently pushing the boundaries of medical education and procedural rehearsals.Architecting Low-Latency Force Feedback Systems To achieve surgical-grade precision, we must look at the underlying software architecture. Traditional game engines, while robust for visual fidelity, often struggle with the 1kHz to 3kHz update rates required for realistic haptic interaction. For stable haptic rendering, the system must calculate the collision response and command the haptic device motors at high frequencies to prevent "jitter" or "ghosting" effects. In a professional-grade simulation, the stack usually resides in a real-time operating system (RTOS) or a heavily patched Linux kernel with PREEMPT_RT capabilities. The communication between the haptic device (such as a Force Dimension delta.3 or similar kinesthetic input) and the physics engine is the bottleneck. We utilize low-level C++ wrappers to bypass the overhead of middleware layers, communicating directly through serial or high-speed USB HID descriptors to manage force vectors. The integration of these forces relies on the "proxy" method, where a virtual cursor (the proxy) is constrained by virtual objects, and the haptic device is pulled toward this proxy by a spring-damper model. The equation of motion is governed by $F = k(x_{proxy} - x_{device}) + b(v_{proxy} - v_{device})$, where $k$ is the stiffness of the virtual surface and $b$ is the damping coefficient. Implementing this in a modular way requires robust configuration management. # haptic_controller_config.yaml simulation_params: haptic_update_rate_hz: 2000 stiffness_max_n_mm: 500.0 damping_coefficient: 0.15 physics_engine: "SOFA-Framework" input_device: vendor_id: "0x145f" product_id: "0x0001" polling_rate_us: 500 latency_monitoring: enabled: true threshold_ms: 10 alert_log: "/var/log/haptic_lag.log"This configuration ensures that the simulation engine is decoupled from the rendering thread. By pinning the haptic loop to a dedicated CPU core using taskset or cgroups, we isolate the real-time constraints from the heavy lifting of visual GPU compute, which is a common failure point in poorly optimized academic implementations. The Physics of Soft-Tissue Deformation Simulating the mechanical response of soft tissue is fundamentally a problem of Finite Element Method (FEM) optimization. When a surgeon performs a palpation task, the tissue must deform non-linearly. Standard rigid-body physics is inadequate here. In the current iteration of high-fidelity simulators, we rely on tetrahedral mesh models where each element's stiffness and elasticity are derived from real-world biomechanical datasets. The computational burden of calculating these deformations in real-time is immense. To solve this, researchers are turning to mass-spring models or Position Based Dynamics (PBD), which trade some physical accuracy for superior performance. However, for surgical precision, PBD is often insufficient. Therefore, we utilize GPU-accelerated FEM solvers. Using CUDA-based kernels, we can parallelize the computation of the stiffness matrix across thousands of threads. This allows us to handle complex geometries, such as those found in hepatic or cardiac simulations, where tissue boundaries are constantly changing. Furthermore, the "tissue damage" factor—simulating tearing, cutting, or cauterization—requires an adaptive mesh topology. This means the engine must be able to perform dynamic remeshing during the simulation loop without stalling the force feedback. When a surgical tool breaches the skin barrier, the mesh must split, creating new nodes on the fly. Doing this within the 1ms budget is the "Holy Grail" of modern surgical robotics software.Implementing Real-Time Force Feedback in Python While C++ is the standard for the inner loop, Python remains an essential glue language for orchestrating the simulation environments, telemetry, and AI-driven assessment modules. Below is a conceptual implementation of how one might interface with a haptic device driver using a Python wrapper to calibrate resistance based on simulated tissue penetration depth. import time import numpy as npclass HapticForceCalculator: """ Simulates tissue resistance feedback based on depth of penetration. """ def __init__(self, stiffness, threshold): self.stiffness = stiffness # N/mm self.threshold = threshold # depth at which tissue is reached def compute_force(self, penetration_depth): if penetration_depth < self.threshold: return 0.0 # Linear spring model for tissue resistance force = self.stiffness * (penetration_depth - self.threshold) return min(force, 20.0) # Max force cap for safetydef main(): haptic_engine = HapticForceCalculator(stiffness=2.5, threshold=0.5) # Mock loop representing the high-speed haptic thread for _ in range(100): # Current penetration depth fetched from physical device current_depth = np.random.uniform(0, 5.0) force = haptic_engine.compute_force(current_depth) print(f"Depth: {current_depth:.2f}mm | Applied Force: {force:.2f}N") time.sleep(0.01) # Simulated 100Hz frequency loopif __name__ == "__main__": main()This code snippet illustrates the fundamental logic: we map physical inputs to force outputs using a bounded model. In a production environment, this compute_force function would be replaced by a call to a C++ binary compiled via Pybind11 to ensure the latency remains within the safety envelope. The safety factor is non-negotiable; in a medical context, an unstable haptic loop can cause the device to oscillate violently, potentially causing injury to the user. Predictive AI for Procedural Assessment Beyond simple kinesthetic simulation, the industry is moving toward AI-driven procedural assessment. By analyzing the force data streams, we can detect if a trainee is using too much force during a suture, a common error in beginner surgical students. This is where the intersection of GitHub-trending time-series analysis tools and medical telemetry becomes vital. We treat the stream of force vectors as a sequence of events. Using Long Short-Term Memory (LSTM) networks or Transformers, we can identify "micro-patterns" of inefficiency. For instance, a novice surgeon might exhibit "tremor" or "hesitation" that is invisible to the human eye but clearly defined in the frequency domain of the force feedback data. By processing this data through a lightweight inference engine deployed on the edge, we provide the trainee with immediate, actionable feedback. This isn't just about training; it is about objective certification. We are creating a pipeline where surgeons can be graded on their "dexterity score" based on data that is immutable and verifiable. This shifts surgical education from a subjective, mentorship-based apprenticeship to an evidence-based, data-driven mastery. Challenges in Scaling and Deployment The deployment of these systems in hospitals globally faces two primary hurdles: the prohibitive cost of high-fidelity hardware and the lack of standardization in software protocols. Currently, each manufacturer of robotic surgical hardware maintains its own proprietary software stack. This silos the data, preventing the widespread adoption of AI-trained surgical models. To overcome this, we advocate for an open-source standard for haptic communications, similar to how ROS (Robot Operating System) revolutionized industrial robotics. By standardizing the way force-feedback devices interact with simulation engines, we allow for cross-platform compatibility. A trainee could theoretically use a generic haptic controller to practice on a simulation designed for a high-end, proprietary console, provided the interface specifications align. We must also address the "networked" surgical reality. If training is to be remote, we face the jitter of the public internet. This brings us back to the importance of the local simulation engine. The server should only synchronize high-level state changes, while the low-level force-feedback loop remains local to the machine to ensure no disruption in the feel of the simulation.Closing Perspectives on Surgical Evolution The convergence of haptic fidelity, GPU-accelerated physics, and AI-driven analytics represents the next frontier in medicine. We are not just building tools to teach surgery; we are creating the digital infrastructure upon which the future of interventionist medicine will rely. The challenges ahead are significant—specifically in maintaining sub-millisecond stability while increasing the complexity of simulated biological materials—but the path forward is clear. By prioritizing low-latency architecture, embracing open-source simulation standards, and rigorously measuring performance through high-frequency telemetry, we ensure that the next generation of surgeons is equipped with the precision required to handle the delicate intricacies of human biology. The digital scalpel is as much an instrument of software as it is of steel. As we refine these systems, we move closer to a reality where the divide between the virtual rehearsal and the real-world operation is almost entirely erased, promising safer, faster, and more effective outcomes for patients worldwide. The engineering community has a profound responsibility to refine these technologies with the same level of care that a surgeon brings to the operating table, ensuring that our code saves lives as effectively as any manual technique.#Robotics #MedTech #AI #Haptics #SurgerySimulation #DeepTech #EngineeringInnovation Related InsightsThe Symphony of Keystrokes: The Ultimate Guide to Mechanical Keyboards Industrial Metaworlds: How AI-Driven Digital Twins Are Redefining Real-Time Factory Automation Energy-Harvesting IoT: Powering Sensors Without Batteries Using Ambient Intelligence and Self-Sustaining Circuits{ "@context": "https://schema.org", "@type": "FAQPage", "mainEntity": [ { "@type": "Question", "name": "What is the main focus of The Digital Scalpel: Architecting High-Fidelity Haptic Feedback in Robotic Surgery Simulation?", "acceptedAnswer": { "@type": "Answer", "text": "An expert analysis on the engineering of force-feedback systems, integrating sub-millisecond latency protocols and kinesthetic simulation for surgical mastery." } }, { "@type": "Question", "name": "Who authored the comprehensive guide on The Digital Scalpel: Architecting High-Fidelity Haptic Feedback in Robotic Surgery Simulation?", "acceptedAnswer": { "@type": "Answer", "text": "This detailed article and its insights were carefully researched and authored by Amara Okafor." } }, { "@type": "Question", "name": "Where can I find more related content about Technology?", "acceptedAnswer": { "@type": "Answer", "text": "You can explore more articles, detailed reviews, and similar insights by browsing the Related Insights section at the bottom of this article or visiting our dedicated Technology category page." } } ] }