Showing Posts From
Micrologistics
-
 David O'Connor
- 16 Sep, 2026 11:38
The Silent Urban Revolution: Architecting Agentic Societies for Autonomous Last-Mile Delivery
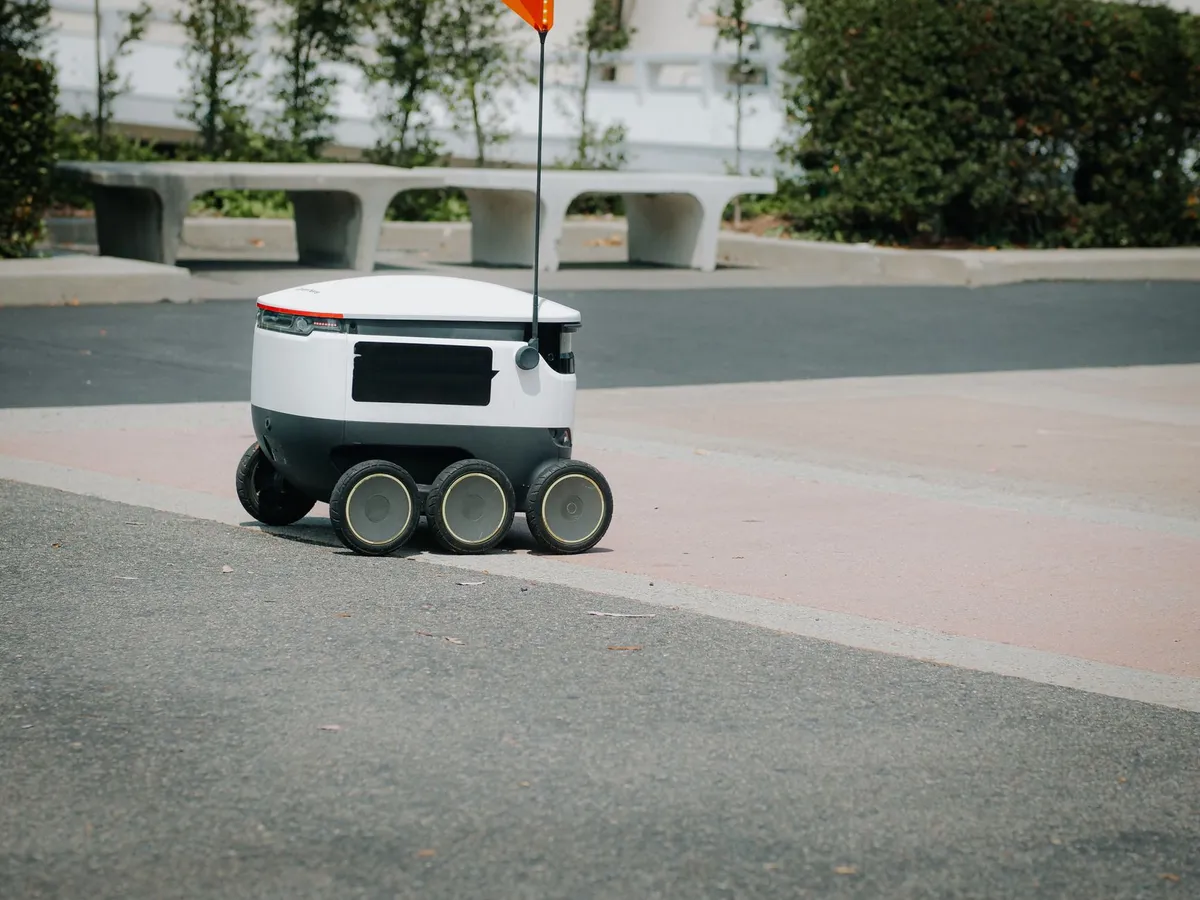
The Concrete Jungle's New Inhabitants The cadence of urban delivery is shifting beneath our feet. For decades, the "last mile" has remained the most expensive and inefficient node in the global supply chain, tethered to the constraints of human labor, traffic congestion, and the volatility of unpredictable urban environments. As we pivot toward an era of dense, autonomous micro-logistics, we are not merely deploying robots; we are birthing an "agentic society." These systems, comprised of autonomous fleets navigating public walkways, must balance high-fidelity spatial awareness with the complex social dynamics of shared spaces. Imagine a sidewalk crowded with pedestrians, cyclists, and automated couriers. Each robot operates on behalf of a principal—a delivery service, a retail aggregator, or a local merchant—whose objectives may only partially align with those of its peers. The core challenge is no longer just obstacle avoidance; it is the orchestration of decentralized agents in an environment where trust is non-existent, communication is unreliable, and the cost of a "social" error—such as blocking a wheelchair ramp or failing to yield—carries severe societal and legal weight. To succeed, we must move beyond simple reactive control loops. We are entering the age of World-Action Models (WAMs) that can predict future states with granular precision, coupled with social harnesses that enforce behavioral constraints, ensuring that the efficiency of micro-logistics does not come at the cost of urban order. Navigating the World through Modality-Autoregressive Intelligence At the heart of modern robotics lies the transition from pure pixel-based observation to modality-rich reasoning. Traditional approaches, which rely heavily on massive RGB frame buffers, often suffer from high computational overhead and suboptimal spatial understanding. Our current research trajectory, specifically through Modality-Autoregressive (ModAR) frameworks, suggests that the future of micro-logistics lies in denoising latent modalities—such as point tracks, DINO features, and depth maps—before committing to an action. By leveraging ModAR, we enable robots to simulate future trajectories with significantly higher success rates while reducing training FLOPs by orders of magnitude compared to pretrained video-model counterparts. In an urban delivery context, this is transformative. A robot equipped with ModAR does not just "see" an approaching pedestrian; it tracks point-features across depth planes, allowing for the anticipation of human intent in dense crowds. The computational efficiency of ModAR is critical for edge deployment. Because these models can run on localized, power-constrained hardware, we avoid the latency pitfalls of cloud-dependent decision-making. By conditioning future actions on previous modality generations, the agent maintains a fluid, autoregressive world model that adjusts in real-time to the chaotic, stochastic nature of city sidewalks. Implementing the Social Harness Layer Autonomous agents, despite their competency, are susceptible to failure when interacting with others whose objectives deviate from their own. An "honest" robot might attempt to optimize for delivery speed, while a faulty agent—or one incentivized for disruptive behavior—could effectively stall traffic flow. To mitigate this, we propose a multi-layered social harness. This harness acts as an intermediary, sitting between the agent’s internal execution logic and the raw communication primitives (the "speech" layer). The social harness provides three critical functions: proactive failure prevention, runtime invalid message detection, and post-facto forensic accountability. In a micro-logistics network, this means every communication—whether it is a sensor-sharing handshake between two robots or a trajectory negotiation—is mediated through a set of social constraints defined at the architecture level, not the agent level. import torch import torch.nn as nnclass SocialHarnessLayer(nn.Module): """ A behavioral constraint engine for autonomous delivery agents. Enforces compliance with safety protocols and social norms. """ def __init__(self, agent_id, compliance_threshold=0.95): super().__init__() self.agent_id = agent_id self.threshold = compliance_threshold def validate_trajectory(self, proposed_path, environment_context): # Check against local safety primitives (e.g., collision with static obstacles) if not self._check_static_bounds(proposed_path): return False, "Violation: Static constraint collision" # Inspect for socially disruptive intent (e.g., high-speed maneuvering in crowds) if self._detect_social_disruption(proposed_path, environment_context): return False, "Violation: Social throughput interference" return True, "Success" def _detect_social_disruption(self, path, context): # Implementation of social norm heuristic checks # Returns True if the path disrupts pedestrian flow return False By decoupling the "personal harness" (private objectives) from the "social harness" (system-wide norms), we enable a modular infrastructure where individual robot manufacturers can iterate on their control policies without compromising the collective stability of the logistics network. Infrastructure Deployment and Edge Orchestration Deploying these agents in a live urban theater requires more than just high-quality AI; it requires a robust, scalable orchestration layer. We must move away from monoliths and toward micro-services, where the robotic agent acts as a compute node. Using a combination of Kubernetes (K3s) for orchestration and lightweight message queuing, we can manage global fleet status while keeping safety-critical decisions local to the device. The deployment configuration below demonstrates how we might isolate the social harness container from the primary vision-action model, ensuring that even if the ModAR layer experiences a kernel panic or model degradation, the social safety supervisor remains operational, forcing the robot into a "fail-safe" stop state. # docker-compose.yaml for edge delivery units version: '3.8'services: perception-modar: image: micro-logistics/modar-engine:v2.1 deploy: resources: limits: memory: 4096M command: --model-type DINO_DEPTH_V4 --gpu-count 1 social-harness: image: micro-logistics/social-safety-harness:v1.0 restart: always environment: - TRUST_BOUNDARY_POLICY=STRICT - LOG_LEVEL=DEBUG volumes: - ./logs:/var/log/harness depends_on: - perception-modar comms-bridge: image: ros2/foxy-base network_mode: "host" environment: - RMW_IMPLEMENTATION=rmw_cyclonedds_cppThis architecture ensures that communication primitives—the "speech"—are monitored. In an agentic society, if an agent transmits data that violates the social harness (e.g., an incorrect obstacle-free flag designed to trick a competitor), the social harness logs the incident, triggers a cryptographic proof of the violation, and immediately severs the agent's interaction capability within the local cluster. Challenges in Multi-Agent Trust and Verification The most significant hurdle to widespread urban delivery is the "Trust Boundary." When different logistics providers (e.g., Amazon, DoorDash, or local autonomous fleets) share the same physical infrastructure, their underlying agents may have misaligned incentives. One company might prioritize battery life, while another prioritizes transit speed. In such a mixed environment, agents must negotiate for path priority. Without a standardized social harness, these negotiations become game-theoretic minefields. An agent could spoof sensor data to gain priority in a crowded crosswalk. To solve this, we rely on immutable logs. By appending all negotiation headers to a local lightweight ledger, we enable post-facto investigation. If a collision occurs, the social harness log acts as a black box that cannot be tampered with by the agent's principal, providing the necessary audit trail for legal and insurance reconciliation in an automated city environment.Furthermore, our experiments indicate that agents benefit from predicting multiple future modalities rather than just the next RGB frame. This is because RGB data is prone to aliasing in high-glare or low-light urban settings. By prioritizing semantic features and point tracks, we create a more robust "world model" that is significantly less likely to succumb to the sensory manipulation that faulty agents might attempt. The "social harness" essentially acts as a runtime verification filter on these world-action predictions. Future Research Directions: Beyond Local Constraints The realization of a fully autonomous agentic society requires significant advancements in decentralized consensus protocols. Currently, we are testing the efficacy of "Federated Learning for Social Norms," where fleets update their collective understanding of urban etiquette—such as how to behave near construction zones or outdoor dining areas—without transmitting sensitive private context. The next frontier for ModAR and social harnesses lies in cross-modal alignment. We are investigating how to incorporate LLM-based reasoning (Large Language Models) to interpret human semantic gestures, such as a hand wave or a nod from a pedestrian. However, this introduces the danger of "Prompt-Injection" at the edge, where a human might try to spoof the robot’s intent. The social harness must therefore extend its capabilities to parse input signals for malicious intent, treating human interaction as a potential security vector. As we look toward 2030, the integration of 6G communication standards will provide the bandwidth necessary for real-time, cross-fleet model synchronization, further tightening the social harness. The goal is to reach a state where the logistics grid is invisible to the pedestrian, operating with the fluidic grace of a school of fish, despite being composed of thousands of autonomous, independently-owned nodes. We are not just building delivery robots; we are encoding the future of urban civil society into the silicon and code of the machines that navigate our streets. The Synthesis of Order and Autonomy The trajectory of robotics in micro-logistics is no longer a matter of hardware miniaturization or raw compute power. We have reached a point where the bottleneck is interaction. By implementing Modality-Autoregressive World-Action Models, we solve the efficiency problem—creating agents that can perceive, predict, and move with unprecedented agility and minimal training costs. By overlaying a robust, multi-layered social harness, we solve the trust and security problem, providing the essential infrastructure needed for agents to coexist in a competitive, heterogeneous ecosystem. The transition from isolated automated experiments to an integrated, agentic urban society depends on our ability to enforce order without stifling the rapid, autonomous decision-making required for real-time logistics. The proposed architectures demonstrate that we can indeed create a "social safety net" for AI. These systems allow for granular auditing, robust runtime verification, and the prevention of malicious exploitation, all while maintaining the sub-millisecond response times required for urban safety. As these technologies mature, we will see the last mile evolve from a chaotic mess of human-error-prone delivery vehicles into a structured, silent, and highly efficient network of autonomous agents, fundamentally rewriting the economics of urban commerce and setting the benchmark for the next decade of robotics deployment in our cities.#AI #Robotics #Logistics #EdgeComputing #Cybersecurity #SoftwareEngineering #FutureTech Related InsightsQuantum Repeaters & Satellite Links: Building the Unhackable Internet of Tomorrow The Ultimate Guide to Custom PC Building: Forging Your Digital Masterpiece Algorithmic Sovereignty: Deconstructing the DAO Paradox in On-Chain Governance{ "@context": "https://schema.org", "@type": "FAQPage", "mainEntity": [ { "@type": "Question", "name": "What is the main focus of The Silent Urban Revolution: Architecting Agentic Societies for Autonomous Last-Mile Delivery?", "acceptedAnswer": { "@type": "Answer", "text": "Exploring the intersection of World-Action Models and social agent frameworks to revolutionize urban micro-logistics at scale." } }, { "@type": "Question", "name": "Who authored the comprehensive guide on The Silent Urban Revolution: Architecting Agentic Societies for Autonomous Last-Mile Delivery?", "acceptedAnswer": { "@type": "Answer", "text": "This detailed article and its insights were carefully researched and authored by David O'Connor." } }, { "@type": "Question", "name": "Where can I find more related content about Technology?", "acceptedAnswer": { "@type": "Answer", "text": "You can explore more articles, detailed reviews, and similar insights by browsing the Related Insights section at the bottom of this article or visiting our dedicated Technology category page." } } ] }